
Downloads · 30 days
0
zachL1/Metric3D
Metric3D is a depth estimation model from zachL1. Use it for the depth estimation task on the model card, and read the license before you ship it in a product. The card lists the license as bsd-2-clause.
Official Model card of Metric3Dv1 and Metric3Dv2:
Downloads · 30 days
0
Access
Public
Updated Apr 17, 2024
Repo size
2.7 GB
Likes
23
Public
Click a slice to open those files.
.pth2.6 GB · 98%
From the Hugging Face model README
Official Model card of Metric3Dv1 and Metric3Dv2:
[1] Metric3D: Towards Zero-shot Metric 3D Prediction from A Single Image
[2] Metric3Dv2: A Versatile Monocular Geometric Foundation Model for Zero-shot Metric Depth and Surface Normal Estimation
<!-- <div style="display: flex; justify-content: flex-start; align-items: center;"> <a href='https://jugghm.github.io/Metric3Dv2'><img src='https://img.shields.io/badge/project%20page-@Metric3D-yellow.svg' style="margin-right: 5px;"></a> <a href='https://arxiv.org/abs/2307.10984'><img src='https://img.shields.io/badge/arxiv-@Metric3Dv1-green' style="margin-right: 5px;"></a> <a href='https:'><img src='https://img.shields.io/badge/arxiv (on hold)-@Metric3Dv2-red' style="margin-right: 5px;"></a> <a href='https://huggingface.co/spaces/JUGGHM/Metric3D'><img src='https://img.shields.io/badge/%F0%9F%A4%97%20Hugging%20Face-Spaces-blue' style="margin-right: 5px;"></a> <a href='https://huggingface.co/zachL1/Metric3D'><img src='https://img.shields.io/badge/%F0%9F%A4%97%20Hugging%20Face-Model%20card-E0FFFF'></a> </div> -->Droid slam codes
Release the ViT-giant2 model
Focal length free mode
Floating noise removing mode
Improving HuggingFace Demo and Visualization
[2024/4/11] Training codes are released!
[2024/3/18] HuggingFace GPU version updated!
[2024/3/18] Project page released!
[2024/3/18] Metric3D V2 models released, supporting metric depth and surface normal now!
[2023/8/10] Inference codes, pre-trained weights, and demo released.
[2023/7] Metric3D accepted by ICCV 2023!
[2023/4] The Champion of 2nd Monocular Depth Estimation Challenge in CVPR 2023
Metric3D is a versatile geometric foundation model for high-quality and zero-shot metric depth and surface normal estimation from a single image. It excels at solving in-the-wild scene reconstruction.
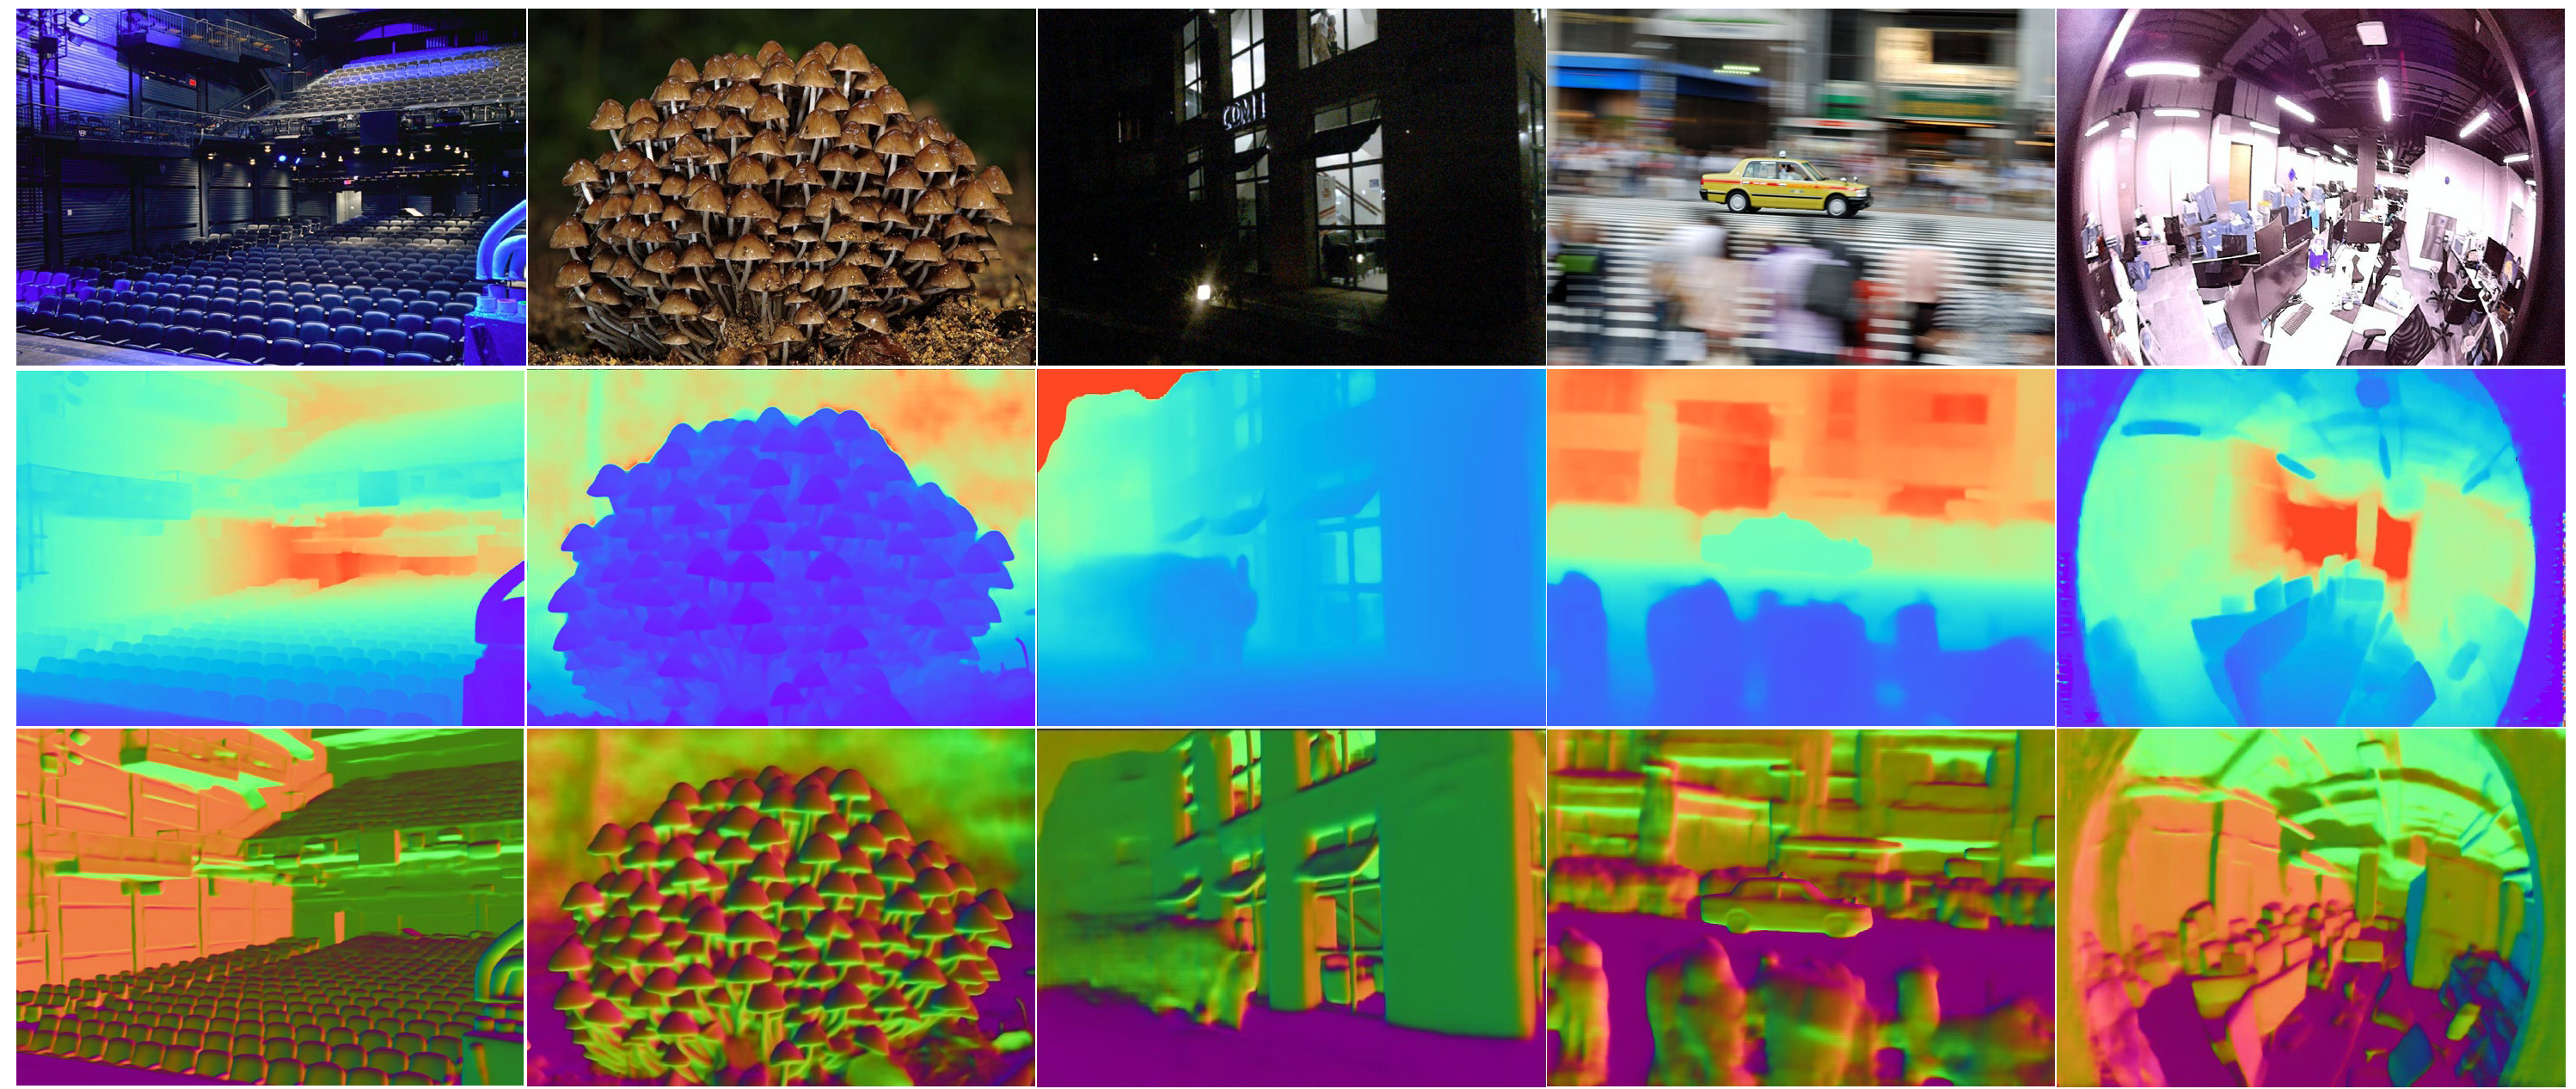
Our models rank 1st on the routing KITTI and NYU benchmarks.
| Backbone | KITTI δ1 ↑ | KITTI δ2 ↑ | KITTI AbsRel ↓ | KITTI RMSE ↓ | KITTI RMS_log ↓ | NYU δ1 ↑ | NYU δ2 ↑ | NYU AbsRel ↓ | NYU RMSE ↓ | NYU log10 ↓ | |
|---|---|---|---|---|---|---|---|---|---|---|---|
| ZoeDepth | ViT-Large | 0.971 | 0.995 | 0.053 | 2.281 | 0.082 | 0.953 | 0.995 | 0.077 | 0.277 | 0.033 |
| ZeroDepth | ResNet-18 | 0.968 | 0.996 | 0.057 | 2.087 | 0.083 | 0.954 | 0.995 | 0.074 | 0.269 | 0.103 |
| IEBins | SwinT-Large | 0.978 | 0.998 | 0.050 | 2.011 | 0.075 | 0.936 | 0.992 | 0.087 | 0.314 | 0.031 |
| DepthAnything | ViT-Large | 0.982 | 0.998 | 0.046 | 1.985 | 0.069 | 0.984 | 0.998 | 0.056 | 0.206 | 0.024 |
| Ours | ViT-Large | 0.985 | 0.998 | 0.999 | 1.985 | 0.064 | 0.989 | 0.998 | 0.047 | 0.183 | 0.020 |
| Ours | ViT-giant2 | 0.989 | 0.998 | 1.000 | 1.766 | 0.060 | 0.987 | 0.997 | 0.045 | 0.187 | 0.015 |
Even compared to recent affine-invariant depth methods (Marigold and Depth Anything), our metric-depth (and normal) models still show superior performance.
| #Data for Pretrain and Train | KITTI Absrel ↓ | KITTI δ1 ↑ | NYUv2 AbsRel ↓ | NYUv2 δ1 ↑ | DIODE-Full AbsRel ↓ | DIODE-Full δ1 ↑ | Eth3d AbsRel ↓ | Eth3d δ1 ↑ | |
|---|---|---|---|---|---|---|---|---|---|
| OmniData (v2, ViT-L) | 1.3M + 12.2M | 0.069 | 0.948 | 0.074 | 0.945 | 0.149 | 0.835 | 0.166 | 0.778 |
| MariGold (LDMv2) | 5B + 74K | 0.099 | 0.916 | 0.055 | 0.961 | 0.308 | 0.773 | 0.127 | 0.960 |
| DepthAnything (ViT-L) | 142M + 63M | 0.076 | 0.947 | 0.043 | 0.981 | 0.277 | 0.759 | 0.065 | 0.882 |
| Ours (ViT-L) | 142M + 16M | 0.042 | 0.979 | 0.042 | 0.980 | 0.141 | 0.882 | 0.042 | 0.987 |
| Ours (ViT-g) | 142M + 16M | 0.043 | 0.982 | 0.043 | 0.981 | 0.136 | 0.895 | 0.042 | 0.983 |
Our models also show powerful performance on normal benchmarks.
| NYU 11.25° ↑ | NYU Mean ↓ | NYU RMS ↓ | ScanNet 11.25° ↑ | ScanNet Mean ↓ | ScanNet RMS ↓ | iBims 11.25° ↑ | iBims Mean ↓ | iBims RMS ↓ | |
|---|---|---|---|---|---|---|---|---|---|
| EESNU | 0.597 | 16.0 | 24.7 | 0.711 | 11.8 | 20.3 | 0.585 | 20.0 | - |
| IronDepth | - | - | - | - | - | - | 0.431 | 25.3 | 37.4 |
| PolyMax | 0.656 | 13.1 | 20.4 | - | - | - | - | - | - |
| Ours (ViT-L) | 0.688 | 12.0 | 19.2 | 0.760 | 9.9 | 16.4 | 0.694 | 19.4 | 34.9 |
| Ours (ViT-g) | 0.662 | 13.2 | 20.2 | 0.778 | 9.2 | 15.3 | 0.697 | 19.6 | 35.2 |
For the ViT models, use the following environment:
pip install -r requirements_v2.txt
For ConvNeXt-L, it is
pip install -r requirements_v1.txt
With off-the-shelf depth datasets, we need to generate json annotaions in compatible with this dataset, which is organized by:
dict(
	'files':list(
		dict(
			'rgb': 'data/kitti_demo/rgb/xxx.png',
			'depth': 'data/kitti_demo/depth/xxx.png',
			'depth_scale': 1000.0 # the depth scale of gt depth img.
			'cam_in': [fx, fy, cx, cy],
		),

		dict(
			...
		),

		...
	)
)
To generate such annotations, please refer to the "Inference" section.
In mono/configs we provide different config setups.
Intrinsics of the canonical camera is set bellow:
    canonical_space = dict(
        img_size=(512, 960),
        focal_length=1000.0,
    ),
where cx and cy is set to be half of the image size.
Inference settings are defined as
    depth_range=(0, 1),
    depth_normalize=(0.3, 150),
    crop_size = (512, 1088),
where the images will be first resized as the crop_size and then fed into the model.
Please refer to training/README.md
| Encoder | Decoder | Link | |
|---|---|---|---|
| v1-T | ConvNeXt-Tiny | Hourglass-Decoder | Coming soon |
| v1-L | ConvNeXt-Large | Hourglass-Decoder | Download |
| v2-S | DINO2reg-ViT-Small | RAFT-4iter | Download |
| v2-L | DINO2reg-ViT-Large | RAFT-8iter | Download |
| v2-g | DINO2reg-ViT-giant2 | RAFT-8iter | Coming soon |
model.pth in weight/.data/gene_annos_kitti_demo.py, which includes 'rgb', (optional) 'intrinsic', (optional) 'depth', (optional) 'depth_scale'.test_*.sh to the *.json path.source test_kitti.sh or source test_nyu.sh.model.pth in weight/.test.sh to the image folder path.source test_vit.sh for transformers and source test.sh for convnets.
As no intrinsics are provided, we provided by default 9 settings of focal length.Because the focal length is not properly set! Please find a proper focal length by modifying codes here yourself.
Because the images are too large! Use smaller ones instead.
First be sure all black padding regions at image boundaries are cropped out. Then please try again. Besides, metric 3D is not almighty. Some objects (chandeliers, drones...) / camera views (aerial view, bev...) do not occur frequently in the training datasets. We will going deeper into this and release more powerful solutions.
@article{hu2024metric3dv2,
  title={A Versatile Monocular Geometric Foundation Model for Zero-shot Metric Depth and Surface Normal Estimation},
  author={Hu, Mu and Yin, Wei, and Zhang, Chi and Cai, Zhipeng and Long, Xiaoxiao and Chen, Hao, and Wang, Kaixuan and Yu, Gang and Shen, Chunhua and Shen, Shaojie},
  booktitle={arXiv},
  year={2024}
}
@article{yin2023metric,
  title={Metric3D: Towards Zero-shot Metric 3D Prediction from A Single Image},
  author={Wei Yin, Chi Zhang, Hao Chen, Zhipeng Cai, Gang Yu, Kaixuan Wang, Xiaozhi Chen, Chunhua Shen},
  booktitle={ICCV},
  year={2023}
}
The Metric 3D code is under a 2-clause BSD License for non-commercial usage. For further questions, contact Dr. yvan.yin [yvanwy@outlook.com] and Mr. mu.hu [mhuam@connect.ust.hk].