
Downloads · 30 days
375
10% of all-time downloads
kiselyovd/vehicle-keypoints
vehicle-keypoints is a keypoint detection model from kiselyovd. Use it for the keypoint detection task on the model card, and read the license before you ship it in a product. It is set up for ultralytics. The card lists the license as other.
A 14-point vehicle-keypoint detector trained on real CarFusion images. Main weights (weights.pt) are YOLO26-pose; the baseline/ directory contains a ViTPose-S reference checkpoint.
Downloads · 30 days
375
10% of all-time downloads
All-time downloads
3.8K
Public
Repo size
610 MB
Likes
1
Trending 1
Click a slice to open those files.
.ckpt577 MB · 94%
From the Hugging Face model README
A 14-point vehicle-keypoint detector trained on real CarFusion images. Main weights (weights.pt) are YOLO26-pose; the baseline/ directory contains a ViTPose-S reference checkpoint.
Live inference · Multi-vehicle annotation explorer · Code & evaluation · Documentation · Synthetic-data study
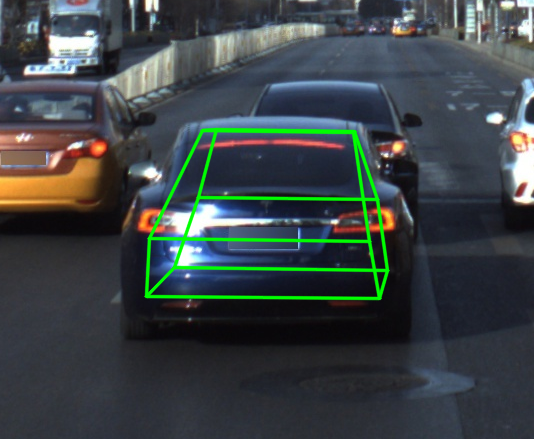
This is an output of the companion geometric PnP baseline, not the output of weights.pt alone. The 3D evaluation protocol uses ApolloCar3D and has separate coverage and domain-shift limits.
from urllib.request import urlopen
from PIL import Image
from huggingface_hub import hf_hub_download
from ultralytics import YOLO

checkpoint = hf_hub_download("kiselyovd/vehicle-keypoints", "weights.pt",
    revision="d277c2d8c9b5ee49d9fed85fe43bdd72b16a0f06", token=False)
model = YOLO(checkpoint)
image = Image.open(urlopen("https://raw.githubusercontent.com/kiselyovd/vehicle-keypoints/f057d0d9f17720a876dd31dece585d08c2e58e02/data/sample/images/car_butler1__16_04881.jpg")).convert("RGB")
results = model.predict(image, device="cpu", imgsz=640, conf=0.25)
for result in results:
    for box, keypoints, score in zip(result.boxes.xywh, result.keypoints.data, result.boxes.conf):
        print(box.tolist(), score.item(), len(keypoints))
The bundled example is a real CarFusion road image. Each detection has a box, confidence score, and 14 (x, y, keypoint confidence) triples. result.boxes.xywh uses center coordinates plus width and height. Dataset annotations use separate visibility codes 0/1/2.
The live Space runs the actual pinned checkpoint on uploaded images. The annotation explorer shows six curated scenes, their original labels and recorded outputs; it is separate from the test benchmark.
The additional overlap scene car_fifth2 / 7_06521 contains three dataset-labelled vehicles. In the pinned CPU replay, the detector returns one foreground-car box and misses the two overlapping vehicles behind it. The Space includes that source scene; run it at imgsz=640, conf=0.25 and inspect the image/result pair. Source records and image hashes are published with the Space, rather than presented as an aggregate failure rate.
Stored CarFusion evaluation; not re-executed as part of this audit
| Metric | Value |
|---|---|
| OKS-mAP | 50.38% |
| OKS-mAP50 | 70.36% |
| [email protected] | 76.06% |
12761 source test frames, OKS sigmas 0.05, PCK threshold 0.05 of bbox diagonal. Historical report is tracked; original training membership and immutable dataset revision were not recorded. Curated demo outputs are separate illustrations.
Evaluation record · Pinned model
<!-- ARTIFACT-MANIFEST:END -->The synthetic-only 24-point model is a separate artifact trained on the UE5 dataset.
In the published matched experiments, adding synthetic frames reduced real-data OKS-mAP by 1.7 pp from a weak checkpoint and 9.5 pp from a strong one. The +2 pp acceptance criterion was not met for that recipe. See the protocol and error analysis.
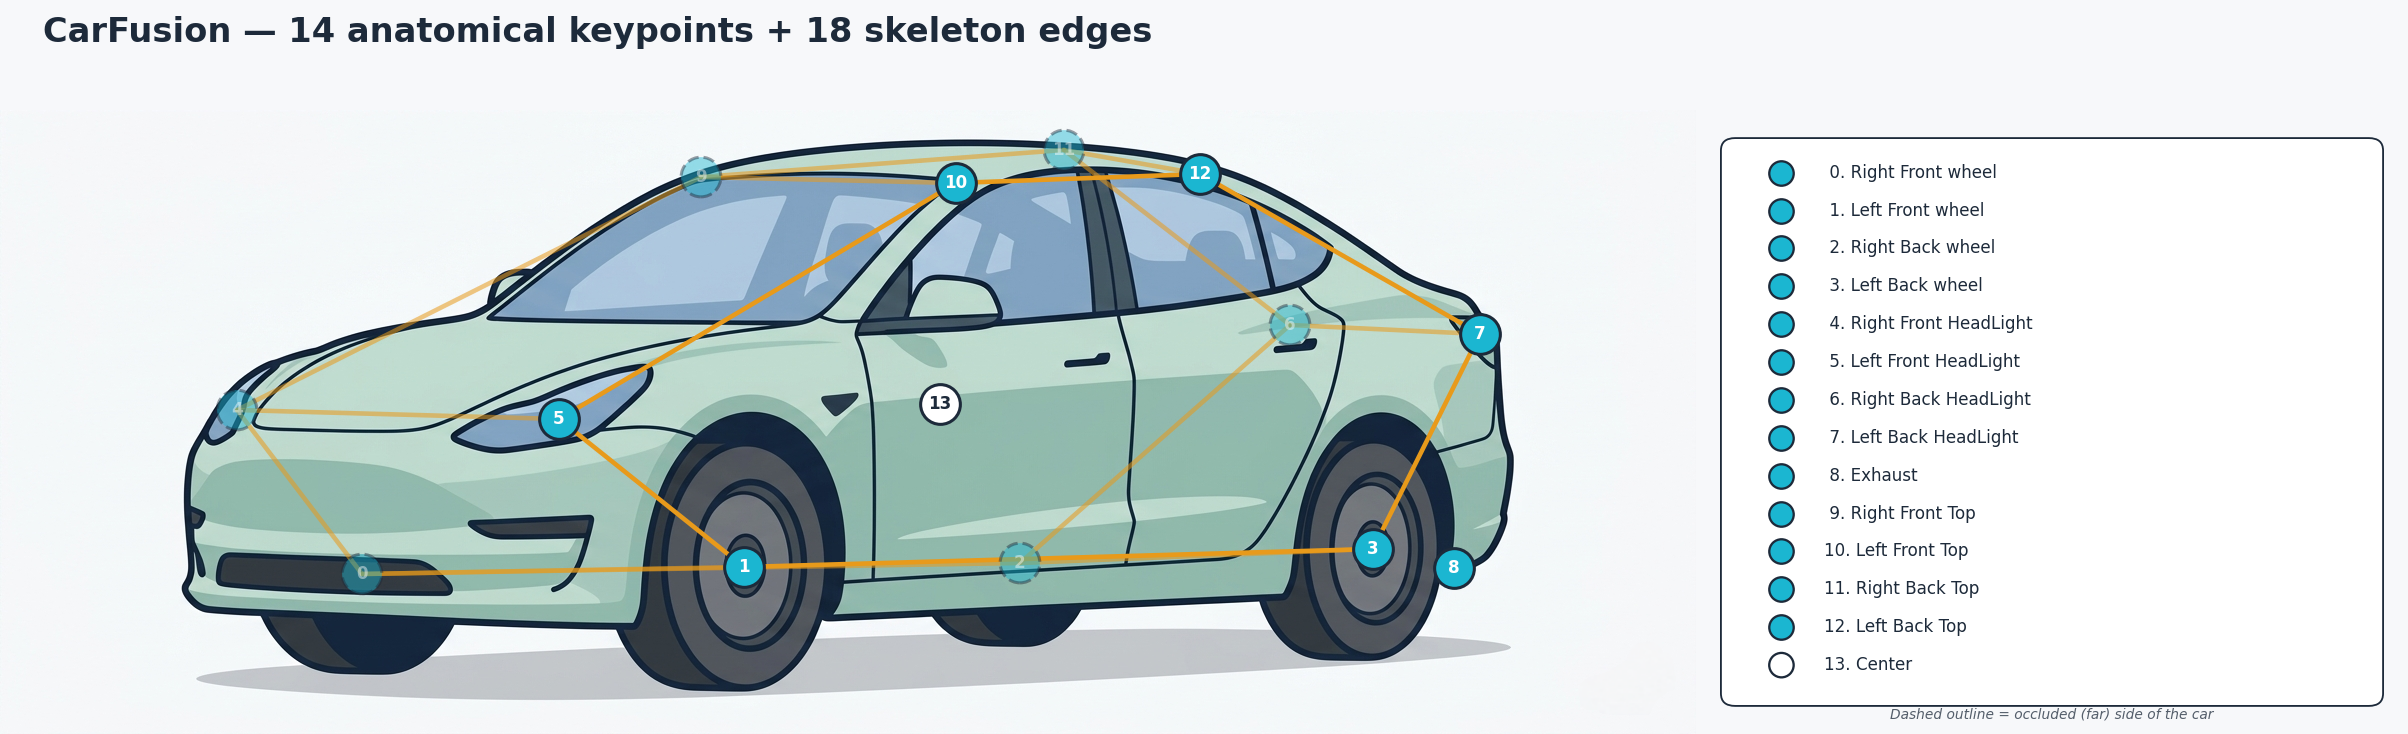
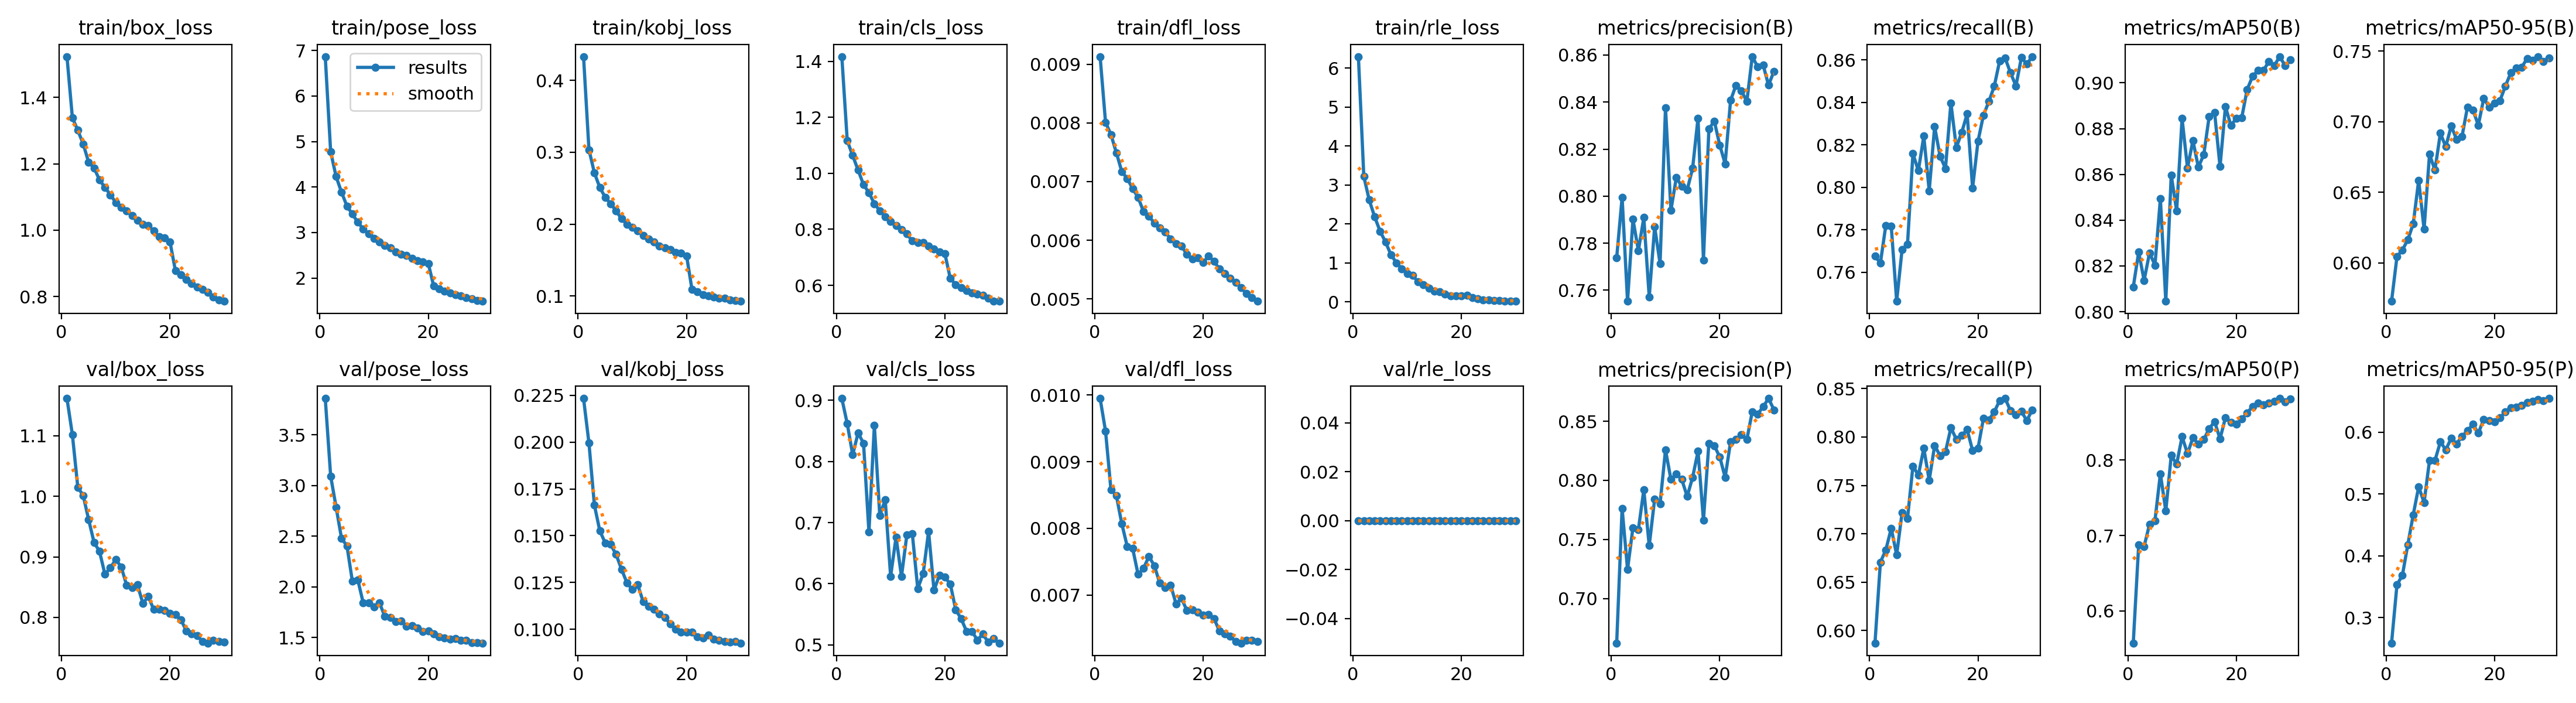
The second image contains training and validation curves. It is not a grid of predicted keypoints.
CarFusion is a limited traffic-scene dataset with scene-level partitions. Its canonical schema covers wheels, lights, roof corners, exhaust, and a body-centre reference point. See dataset preparation and baseline details.
Research and education use. These artifacts have not been validated for safety-critical autonomous-driving use. The 3D companion has limited detector coverage and substantial domain shift.
Project code is MIT. The earlier author weight declaration was MIT; the YOLO component also carries Ultralytics upstream terms (AGPL-3.0 or applicable Enterprise terms). That author declaration does not remove upstream obligations. CarFusion is a separate CMU dataset; no standard dataset license is inferred from the software license. Component details.