
Downloads · 30 days
18
13% of all-time downloads
hrishivish23/giorom-3d-t-elasticity-3d
giorom-3d-t-elasticity-3d is a graph machine learning model from hrishivish23. Use it for the graph machine learning task on the model card, and read the license before you ship it in a product. The card lists the license as mit.
By Hrishikesh Viswanath, Yue Chang, Julius Berner, Peter Yichen Chen, Aniket Bera
Downloads · 30 days
18
13% of all-time downloads
All-time downloads
137
Public
Parameters
2.4M
28.8 MB on disk
Likes
3
Public
Click a slice to open those files.
.pt19.2 MB · 67%
From the Hugging Face model README
By Hrishikesh Viswanath, Yue Chang, Julius Berner, Peter Yichen Chen, Aniket Bera
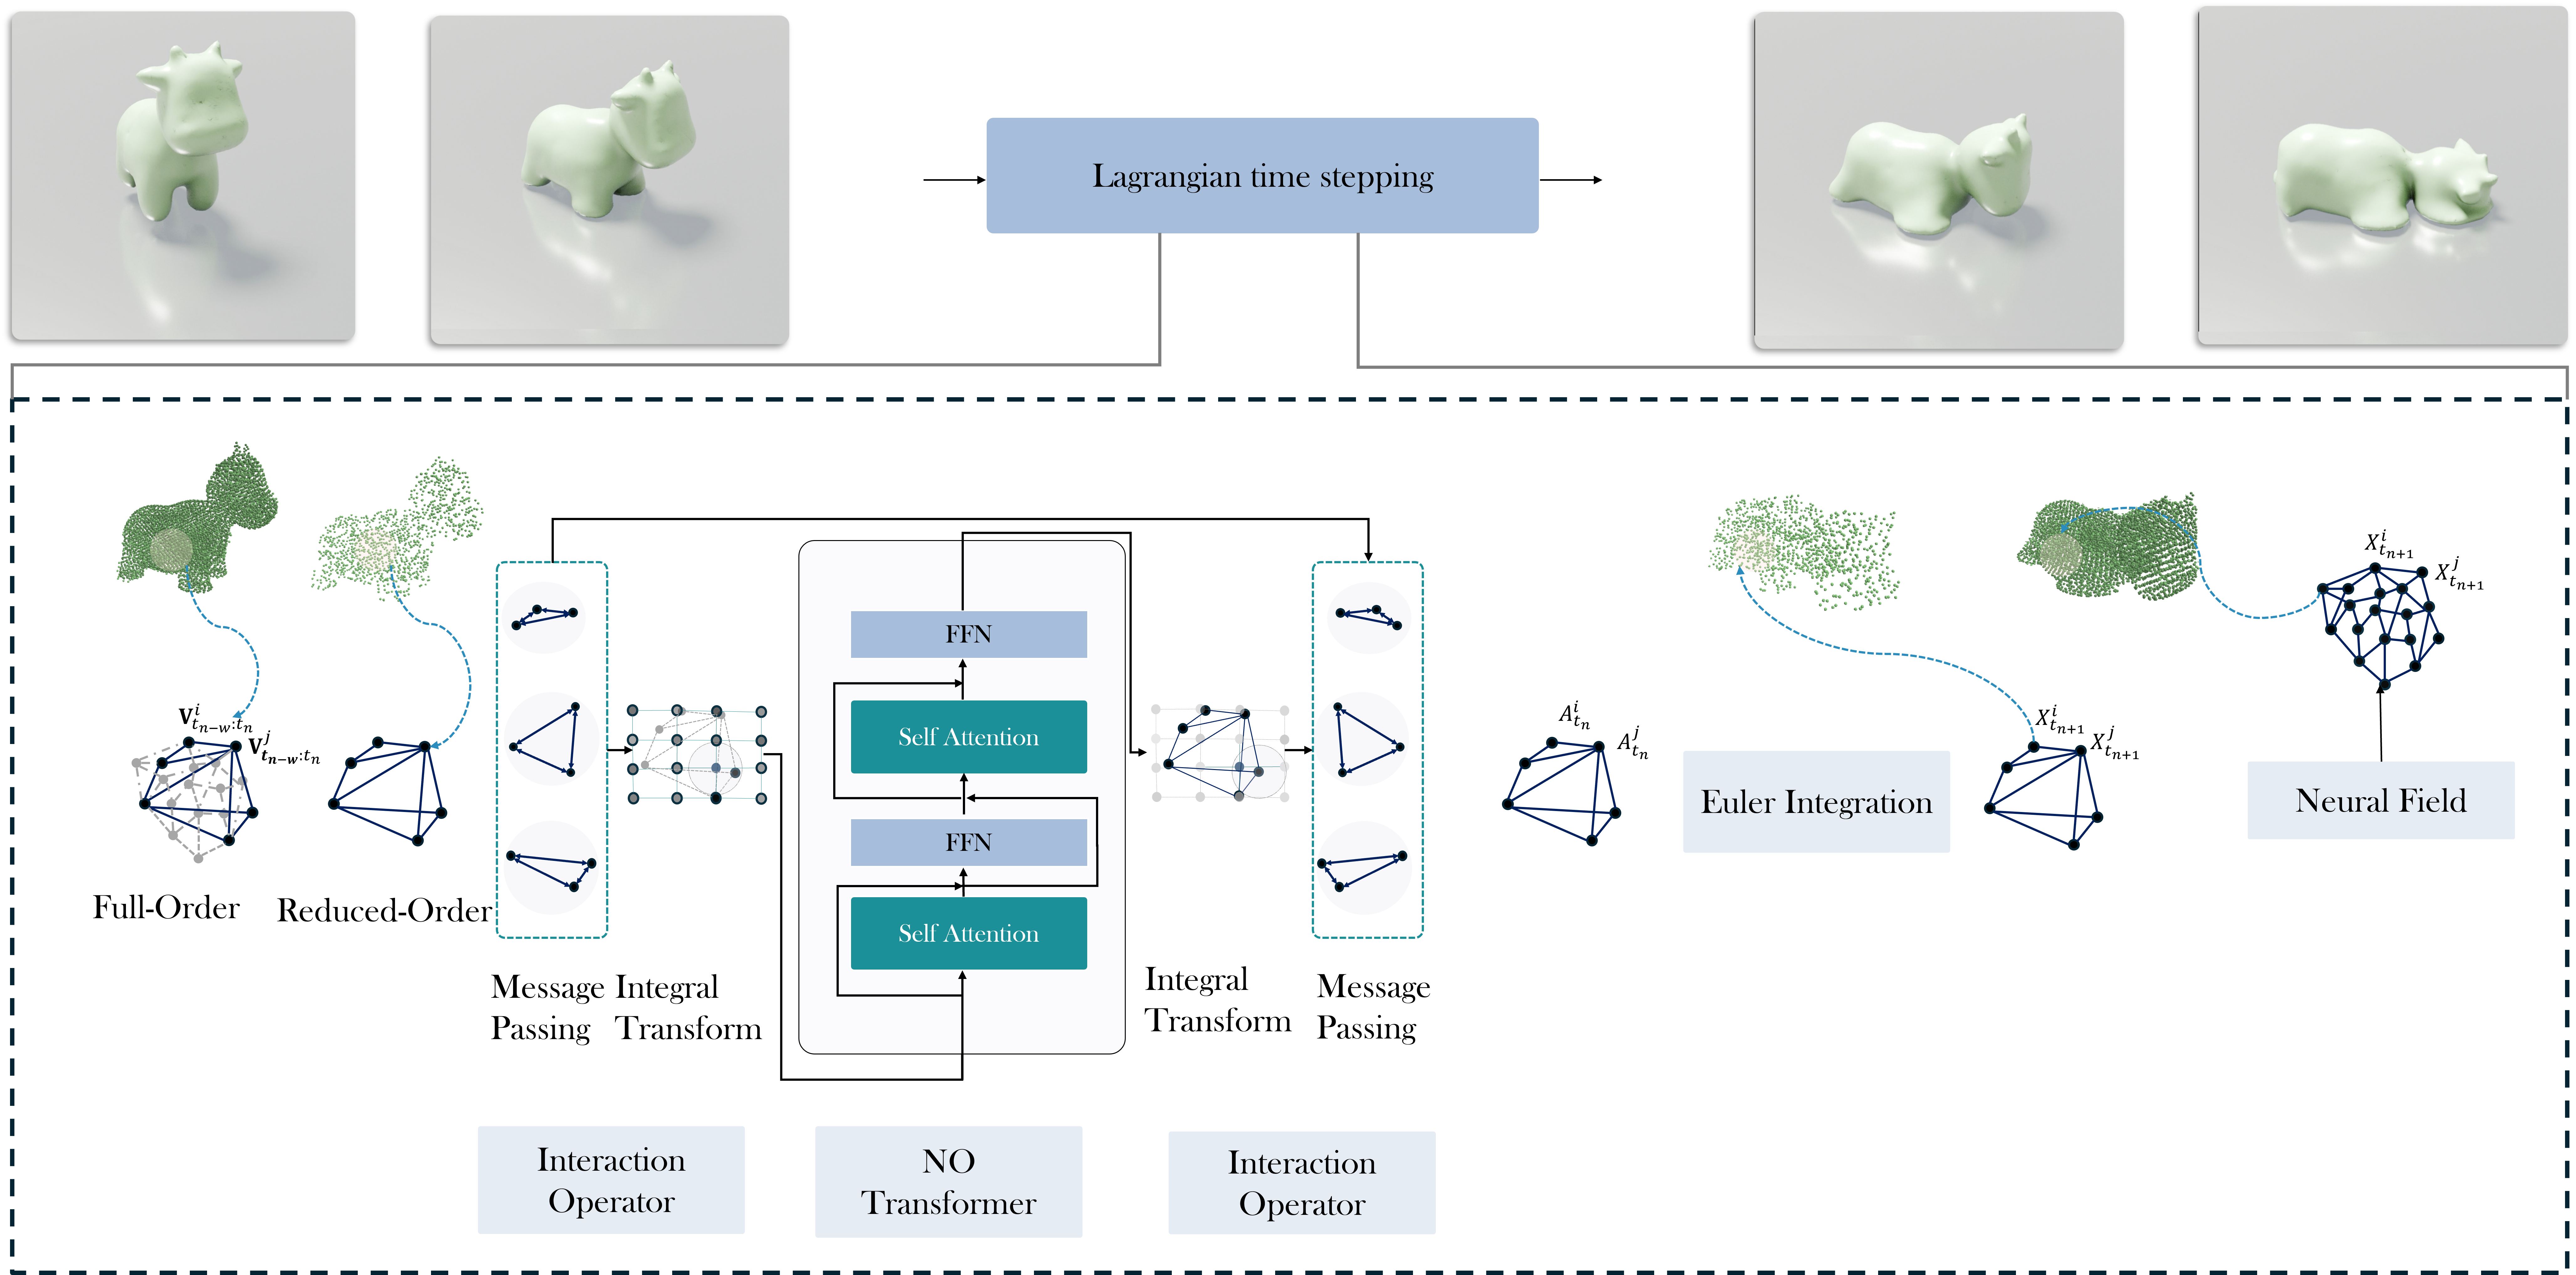
GIOROM is a Reduced-Order Neural Operator Transformer designed for Lagrangian dynamics simulations on highly sparse graphs. The model enables hybrid Eulerian-Lagrangian learning by:
MPM-Verse-MaterialSim-Small/Elasticity3DSmall,⚠ Note: While the model can infer using an integral transform, this repository only provides weights for the time-stepper model that predicts acceleration.
Each variant corresponds to a specific dataset, showcasing the reduction in particle count (n: reduced-order, N: full-order).
| Model Name | n (Reduced) | N (Full) |
|---|---|---|
giorom-3d-t-sand3d-long | 3.0K | 32K |
giorom-3d-t-water3d | 1.7K | 55K |
giorom-3d-t-elasticity | 2.6K | 78K |
giorom-3d-t-plasticine | 1.1K | 5K |
giorom-2d-t-water | 0.12K | 1K |
giorom-2d-t-sand | 0.3K | 2K |
giorom-2d-t-jelly | 0.2K | 1.9K |
giorom-2d-t-multimaterial | 0.25K | 2K |
The model predicts acceleration from past velocity inputs:
Input Shape: [n, D, W]
n: Number of particles (reduced-order, n ≪ N)D: Dimension (2D or 3D)W: Time window (past velocity states)Projected to a uniform latent space of size [c^D, D] where:
c ∈ {8, 16, 32}n - δn ≤ c^D ≤ n + δnThis allows the model to generalize physics across different resolutions and discretizations.
pip install transformers huggingface_hub torch
git clone https://github.com/HrishikeshVish/GIOROM/
cd GIOROM
from models.giorom3d_T import PhysicsEngine
from models.config import TimeStepperConfig

time_stepper_config = TimeStepperConfig()

simulator = PhysicsEngine(time_stepper_config)
repo_id = "hrishivish23/giorom-3d-t-sand3d"
time_stepper_config = time_stepper_config.from_pretrained(repo_id)
simulator = simulator.from_pretrained(repo_id, config=time_stepper_config)
import torch
| Model Name | Model ID |
|---|---|
giorom-3d-t-sand3d-long | hrishivish23/giorom-3d-t-sand3d-long |
giorom-3d-t-water3d | hrishivish23/giorom-3d-t-water3d |
{8×8, 16×16, 32×32}1e-4AdamaxMSE + Physics Regularization (Loss computed on Euler integrated outputs)1M+ steps2If you use this model, please cite:
@article{viswanath2024reduced,
  title={Reduced-Order Neural Operators: Learning Lagrangian Dynamics on Highly Sparse Graphs},
  author={Viswanath, Hrishikesh and Chang, Yue and Berner, Julius and Chen, Peter Yichen and Bera, Aniket},
  journal={arXiv preprint arXiv:2407.03925},
  year={2024}
}
For questions or collaborations:
This model is ideal for fast and scalable physics simulations where full-resolution computation is infeasible. The reduced-order approach allows efficient learning on sparse inputs, with the ability to reconstruct dense outputs using an integral transform model (not included in this repo).