
Downloads · 30 days
0
diasAiMaster/unitree-go2-velocity-flat
unitree-go2-velocity-flat is a reinforcement learning model from diasAiMaster. Use it for the reinforcement learning task on the model card, and read the license before you ship it in a product. It is set up for rsl-rl. The card lists the license as bsd-3-clause.
RL locomotion policy for the Unitree Go2 quadruped robot, trained on flat terrain using PPO.
Downloads · 30 days
0
Access
Public
Updated May 10, 2026
Repo size
29.3 MB
Likes
3
Public
Click a slice to open those files.
.pt27.4 MB · 84%
From the Hugging Face model README
RL locomotion policy for the Unitree Go2 quadruped robot, trained on flat terrain using PPO.
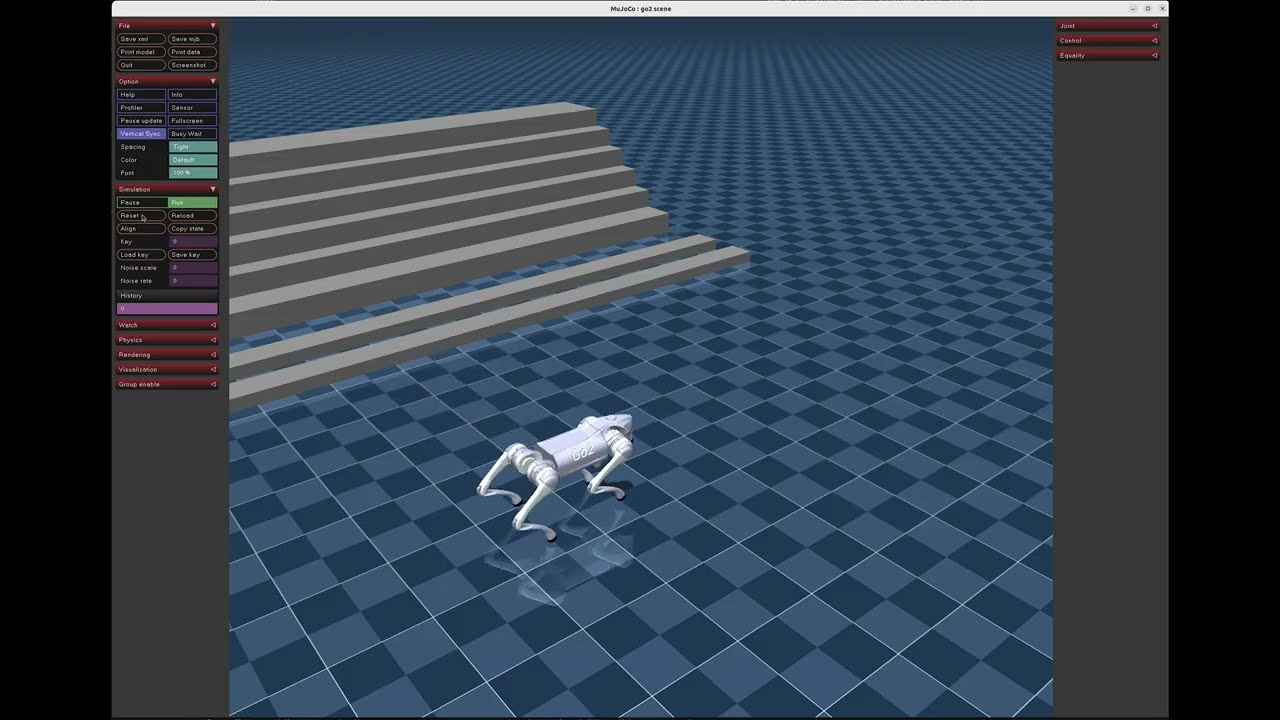
Mjlab-Velocity-Flat-Unitree-Go2| Metric | Value |
|---|---|
| Mean reward | 52.9 |
| Mean episode length | 1000 (max, no falls) |
| Steps/sec | 628K-738K |
| File | Description |
|---|---|
policy.onnx + policy.onnx.data | ONNX model for deployment (go2_ctrl) |
model_500.pt | Final PyTorch checkpoint (best for fine-tuning) |
model_0.pt ... model_400.pt | Intermediate checkpoints every 100 steps |
params/deploy.yaml | Deploy configuration (obs order, action scale, joint mapping) |
params/env.yaml | Environment configuration |
params/agent.yaml | Agent/PPO configuration |
events.out.tfevents.* | TensorBoard training logs |
# Copy ONNX model + deploy config
cp policy.onnx policy.onnx.data \
  unitree_rl_mjlab/deploy/robots/go2/config/policy/velocity/v0/exported/
cp params/deploy.yaml \
  unitree_rl_mjlab/deploy/robots/go2/config/policy/velocity/v0/params/

# Build controller
cd unitree_rl_mjlab/deploy/robots/go2
mkdir -p build && cd build
cmake .. -DCMAKE_BUILD_TYPE=Release && make -j$(nproc)

# Run simulator + controller
cd unitree_mujoco/simulate/build && ./unitree_mujoco
cd unitree_rl_mjlab/deploy/robots/go2/build && ./go2_ctrl --network=lo
Important: This model was trained without
gait_phaseand with action scale 0.5. The defaultdeploy.yamlin unitree_rl_mjlab may differ — useparams/deploy.yamlfrom this repo.
# Place model_500.pt in logs/rsl_rl/go2_velocity/<run_name>/
python scripts/train.py Mjlab-Velocity-Rough-Unitree-Go2 \
  --agent.resume=True \
  --agent.load-run="<run_name>" \
  --agent.load-checkpoint="model_500.pt" \
  --agent.algorithm.learning-rate=1e-4
The upstream unitree_rl_mjlab has bugs that crash multi-GPU training on rough terrain — see Issue #9 and PR #8.